NVIDIA introduces GR00T 2 and Isaac Lab 3.0 for robot learning
The AMW Read
The releases materially update NVIDIA's robotics model and simulation tools, with potential impact across the robotics segment.
NVIDIA introduces GR00T 2 and Isaac Lab 3.0 for robot learning
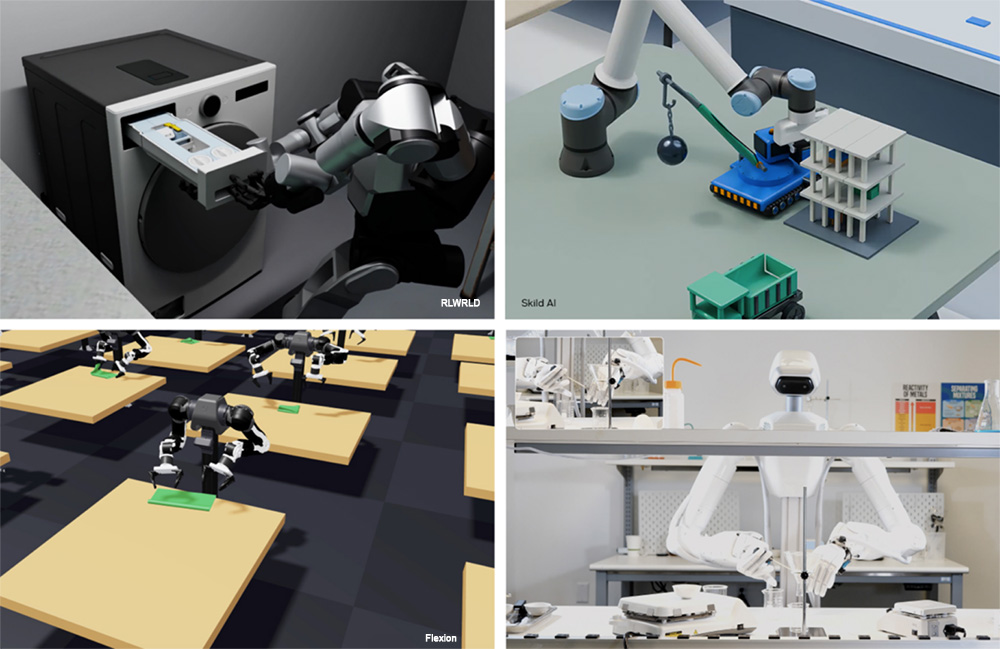
NVIDIA introduced GR00T 2, a world action model for robot manipulation, and Isaac Lab 3.0, an open-source robot learning framework, at the Conference on Robot Learning in Austin. NVIDIA said GR00T 2 was trained on robot and human data, including 100,000 hours of its open-source egocentric data. The company reported an average success rate of 71% across 50 tasks with one demonstration per task and 95% with five.
The releases place NVIDIA across both the embodied model and simulation layers of robotics. GR00T 2 is designed to transfer skills from human demonstrations and between robot bodies, while Isaac Lab 3.0 supports simulation training and reinforcement post-training. Integration with the Newton physics engine adds support for deformable objects such as cables and cloth. Together, those tools address a central challenge for robotics developers: training manipulation skills that can transfer from simulated environments to physical machines.
For builders and investors, the practical test is whether these reported gains hold in specific deployments. NVIDIA said GR00T 2 completed 40 of 50 evaluated tasks at least once without task-specific demonstrations; that result does not establish reliable performance on every attempt. Foxconn is applying the model to server manufacturing, while Siemens is evaluating industrial uses. In a vision-based manipulation benchmark, NVIDIA also reported up to 2.5 times the training throughput of Isaac Lab 2.3 with PhysX. Teams can use these examples to assess performance and training costs against their own tasks.