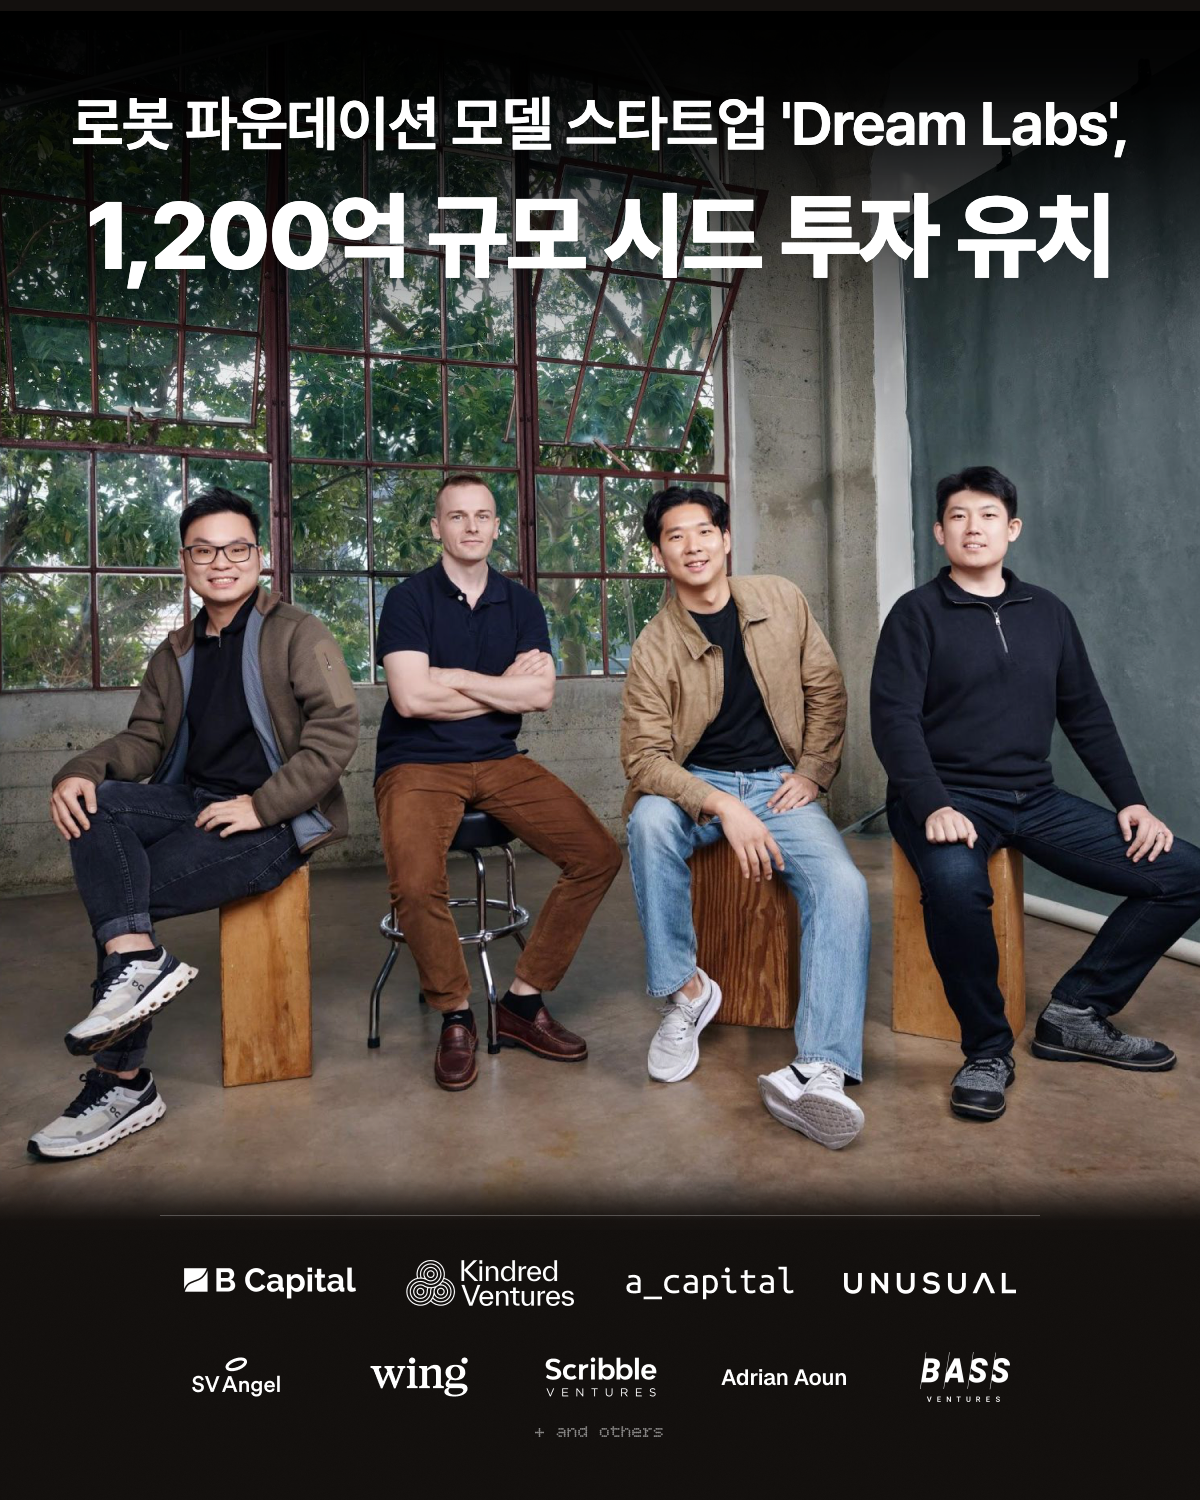
DreamLabs raises $90M to develop a shared intelligence layer for robots
The AMW Read
A $90M seed round and an accessible robotics model introduce a substantial entrant in cross-hardware robot intelligence, although deployment reliability remains unproven by the reported demonstrations.
DreamLabs raises $90M to develop a shared intelligence layer for robots
DreamLabs has raised $90 million, approximately 120 billion won, in seed funding led by B Capital, with participation from Kindred Ventures, A.Capital, Unusual Ventures, SV Angel, Wing VC, Scribble VC and Base Ventures. Founded in April by former Nvidia robotics researchers, the company also unveiled its Dream-1 robotics foundation model and Dream API. Dream-1 converts camera footage and everyday English instructions into robot motor commands. The company plans to spend most of the funding on computing resources to expand supported tasks, robot types and user capacity.
The market significance is the attempt to sell robot intelligence independently of hardware. DreamLabs says Dream-1 learns from videos of people performing everyday tasks, using predictions of what happens next to select robot actions. It says the model currently supports tabletop tasks on robots with two arms and grippers without additional training. This positions DreamLabs in the emerging market for embodied foundation models, where transferring skills across machines could reduce the cost of programming each task. The stated support remains narrower than a general-purpose brain for any robot; broader commercial usefulness still depends on reliable performance across tasks and hardware.
For builders and investors, the concrete test is whether faster setup translates into repeatable work on affordable machines. DreamLabs says it is working with more than 20 hardware companies, including Unitree and Robotis, whose robots cost $2,000–$10,000. Its browser-based Robot Playground lets users remotely operate robots in its San Francisco office. These access points offer ways to assess deployment effort, task completion and failure recovery before treating demonstrations as evidence of production readiness.