RLWRLD Releases DexBench to Evaluate Humanoid Hand Manipulation
The AMW Read
DexBench adds a multi-task evaluation tool for industrial robot manipulation, but its value for physical deployment remains unproven.

RLWRLD Releases DexBench to Evaluate Humanoid Hand Manipulation
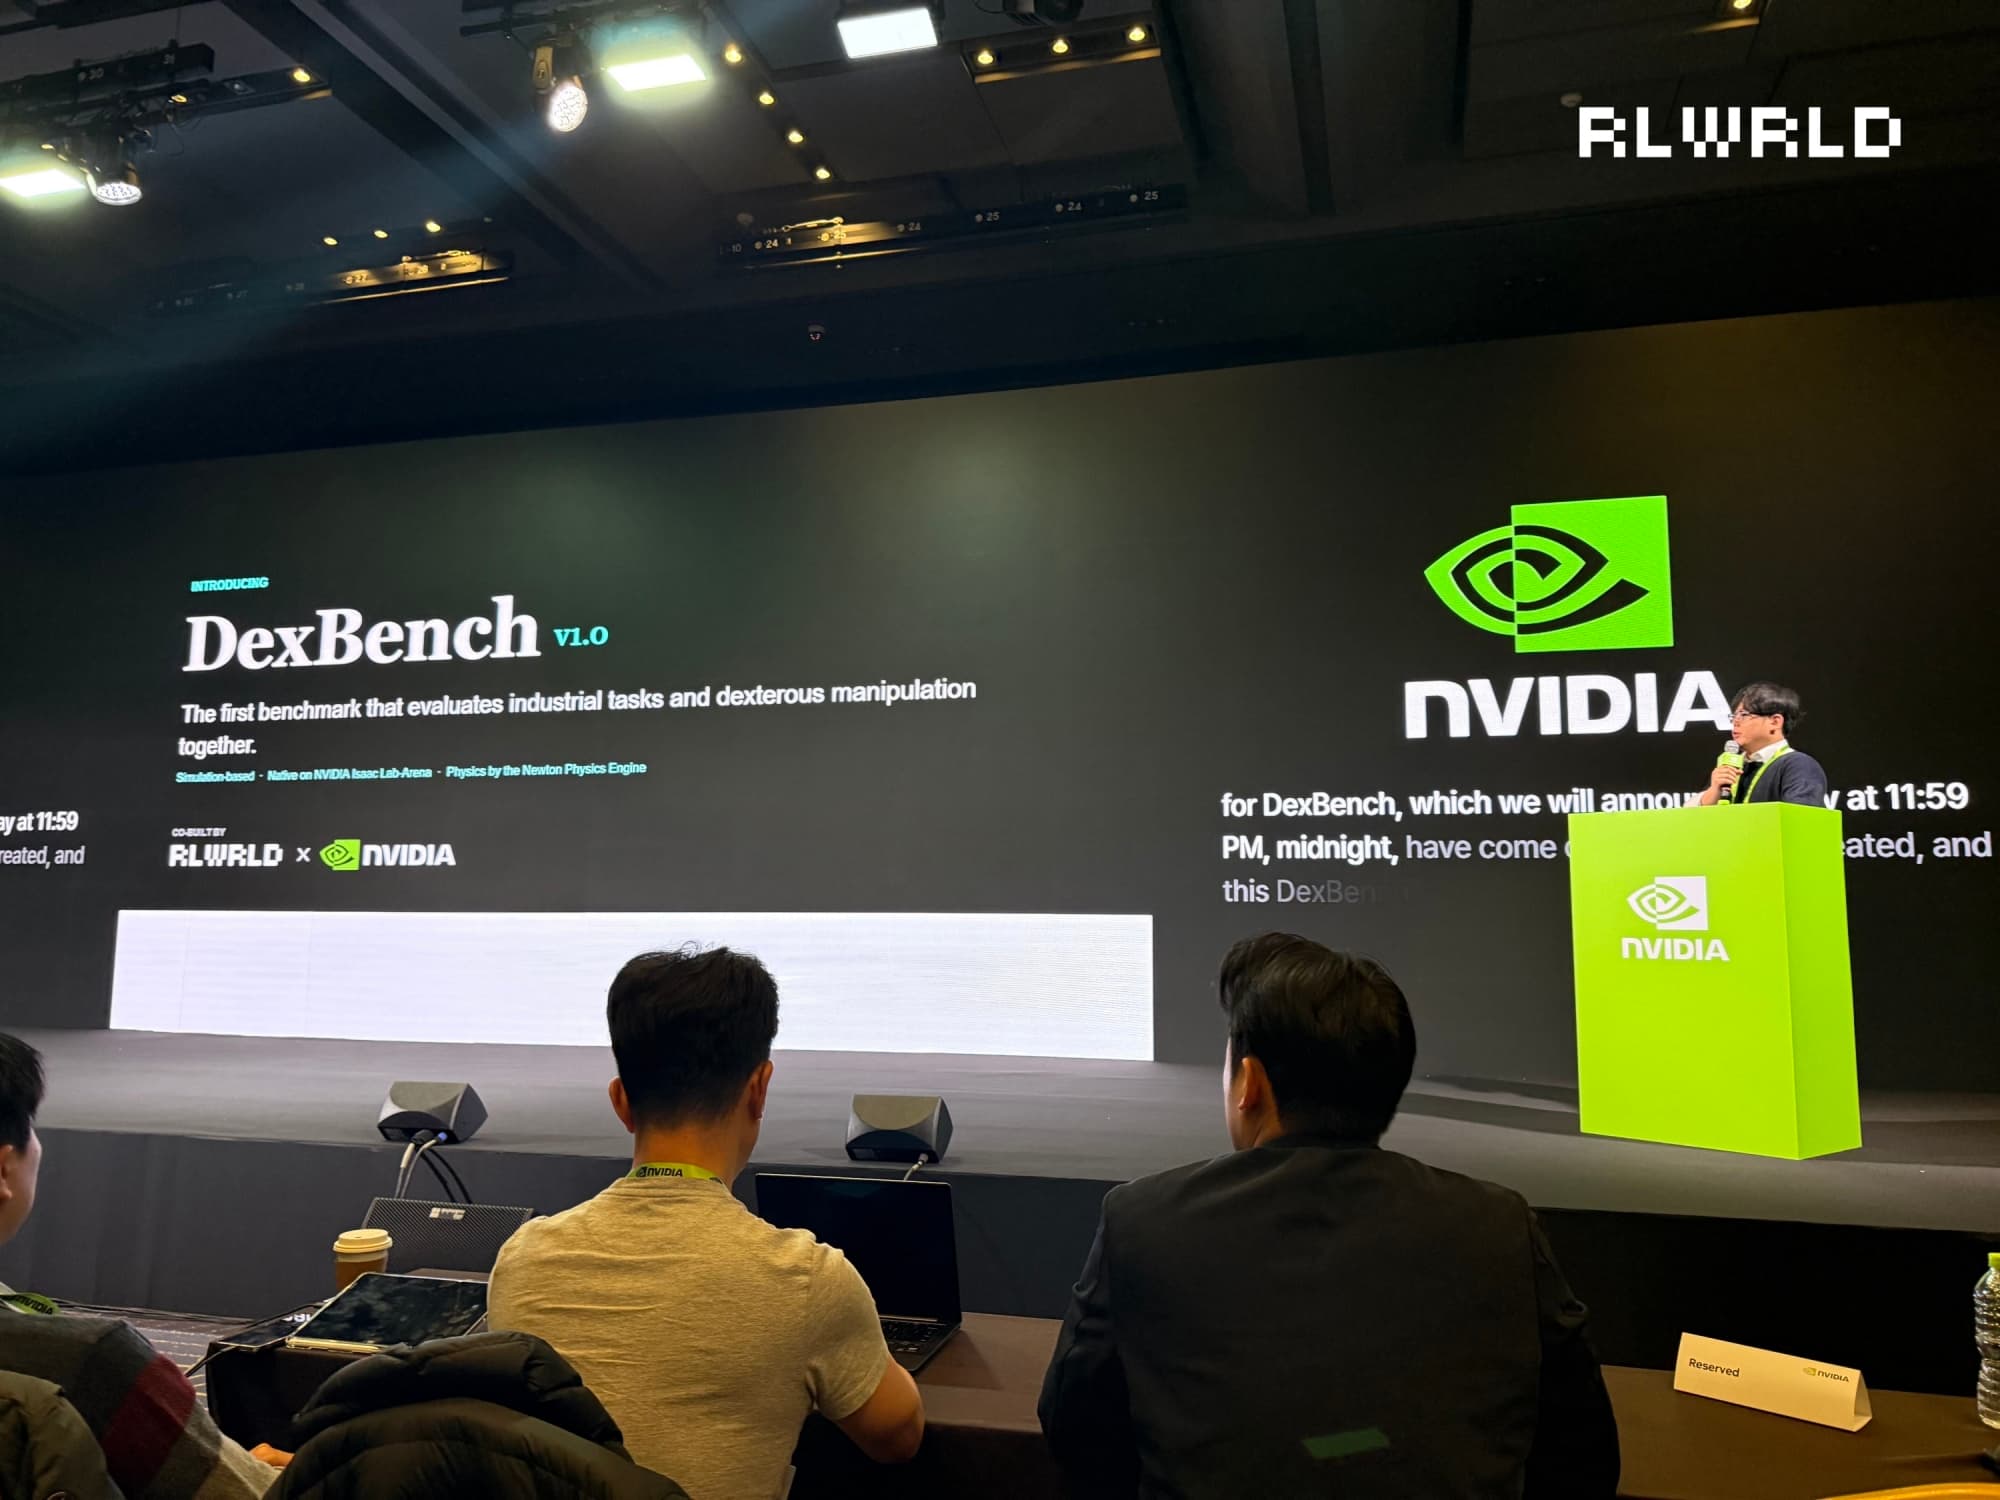
Physical AI company RLWRLD has released DexBench, a simulation benchmark for humanoid robots with five-fingered hands. It covers 15 tasks across retail, logistics, assembly, and hotel food and beverage settings. The tasks include inserting connectors, fastening screws, stacking plates, and pouring liquids. DexBench tests task success and generalization across unfamiliar objects, physical properties, and spatial conditions.
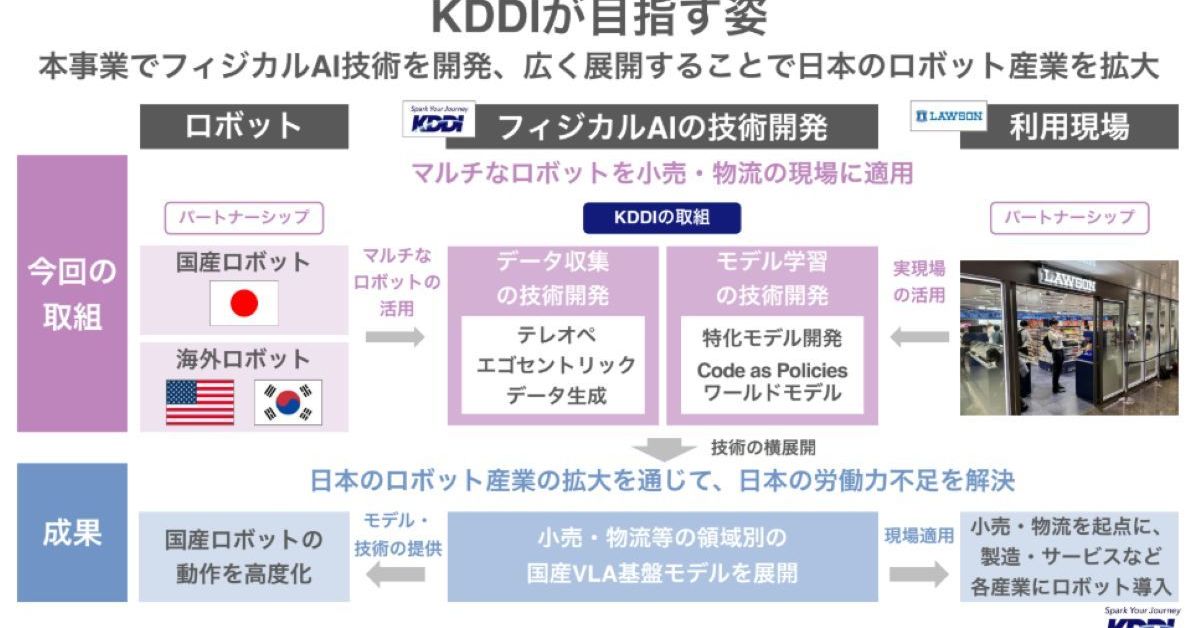
The release adds an evaluation layer to the market for robotics foundation models. A shared benchmark could help developers compare how models handle industrial manipulation, where precise contact and changing conditions matter. DexBench runs on NVIDIA's Isaac Lab-Arena and the Newton physics engine. RLWRLD says Genesis AI and Mimic Robotics are evaluating it through early access. The benchmark extends RLWRLD's work on retail and logistics robotics, where the company and KDDI have identified field data and control as deployment challenges.
For builders and investors, the next test is whether simulated results correspond to performance on physical robots. RLWRLD plans to strengthen that comparison and expand support for robot platforms and hands. It also plans to release code, environments, assets, training data, baseline models, and a leaderboard. The company reports initial results from its RLDX 1.1 model, but the article provides no performance figures. NVIDIA has also announced an investment plan for RLWRLD; its size and timing were not disclosed.